Arduino, running the sketch you wrote
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.

Hardware is all about iteration. Velxio lets you wire a circuit, program the board and run it in seconds, real firmware on a real solver, right in the browser.
DFRobot · M5Stack links on this page are affiliate links: a purchase through them earns Velxio a small commission at no extra cost to you.
Nothing on this page is a scripted animation: the firmware is compiled and executed, and the circuit around it is solved.
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.
arduino-cli or ESP-IDF compiles the sketch, then AVR8, RP2040, RISC-V, Xtensa or ARM executes it instruction by instruction. What the OLED draws and what the serial monitor prints is what the chip actually did.

ngspice compiled to WebAssembly runs a full nodal analysis about 60 times a second. GPIO pins drive real nets, ADC inputs read solved node voltages, and probes report RMS, DC and current wherever you drop them.
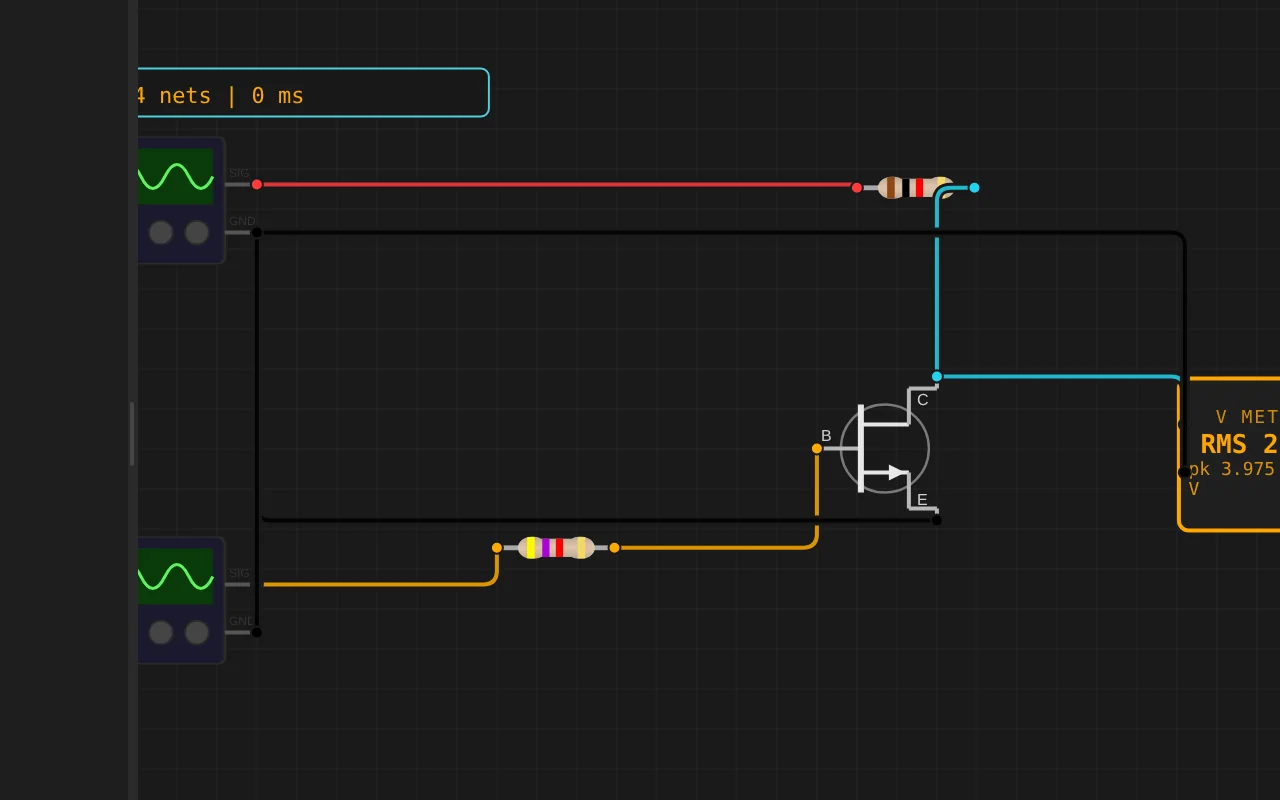
Adders, comparators, decoders, flip-flops and a 1-bit ALU slice: no microcontroller anywhere, just gates, switches and LEDs solved as a real net. The classroom half of electronics, without the breadboard.
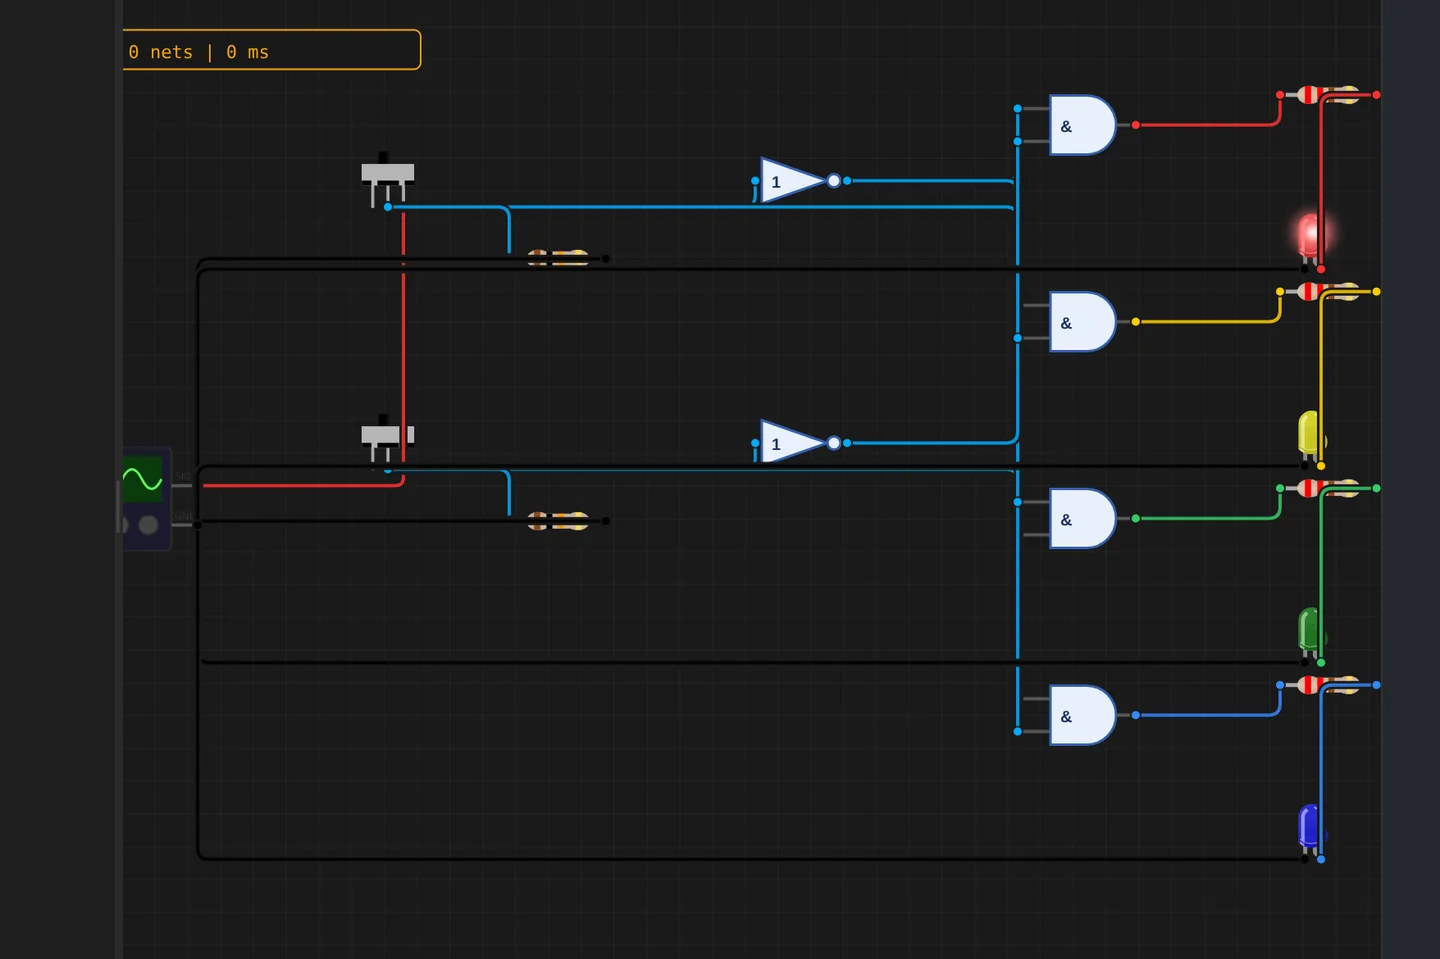
The M5Stack Cardputer with its keyboard, Seeed's round display keeping time, Pimoroni's Badger 2350 driving e-paper, and DFRobot's UNIHIKER M10 in the catalogue alongside them. Their makers sent the hardware so the emulation could be checked against the real thing.
35 boards across 6 CPU architectures — AVR8, ARM Cortex-M, ARM Cortex-A, RISC-V, Xtensa, and Linux. Including partner boards from Pimoroni, M5Stack, Seeed Studio and DFRobot. All running locally, no cloud needed.






One institution contract gives every student in the class a full Pro account. No per-seat checkout, no card details in a classroom.
Private projects, BOM and schematic exports, GitHub Sync and the offline desktop app, for everyone enrolled.
Billed once to your institution, per semester or per year. Volume pricing on request for large cohorts.
Arduino, ESP32, RP2040, STM32, ATtiny and Raspberry Pi, with SPICE analog solved alongside the firmware. Not a sandboxed mock.
The simulator stays free forever, WiFi with internet included. Paid plans unlock the Linux and STM32 boards, custom WiFi networks, the local network gateway and the offline desktop app. Maker and Pro add the AI agent; No AI leaves it out.
Discover the simulator + light AI help.
The full workbench, zero AI. You write every line.
For makers shipping real circuits with AI help.
Private projects, GitHub Sync and BOM exports.
Questions, bugs and ideas: the Discord and the issue tracker are open, and so is every line of the simulator.
Gear motor JGA25 con encoder Hall detras de un L293D en un Uno. Las interrupciones cuentan los flancos A/B y un lazo PI ajusta el duty hasta la consigna.
An interactive Arduino Uno circuit simulation you can run free in your browser on Velxio, by dave.
// Closed-loop speed control of a gear motor, read back through its encoder.
//
// The L293D drives the motor, the Hall encoder reports how fast the output
// shaft really turns, and a PI loop adjusts the duty until the two agree.
// Change TARGET_RPM, or the Gear ratio / Encoder PPR on the part, and watch
// the loop settle again.
#define EN   9   // L293D EN1: PWM sets the speed
#define IN1  7   // direction
#define IN2  8
#define ENC_A 2  // encoder outputs on the two interrupt pins
#define ENC_B 3

const float COUNTS_PER_REV = 11 * 4 * 30;  // PPR x4 decoding x gear ratio

volatile long counts = 0;

// x4 decoding: every edge on either channel is one count, and the other
// channel's level says which way the shaft went.
void onA() { counts += (digitalRead(ENC_A) == digitalRead(ENC_B)) ? -1 : 1; }
void onB() { counts += (digitalRead(ENC_A) == digitalRead(ENC_B)) ? 1 : -1; }

float integral = 0;

void setup() {
  Serial.begin(115200);
  pinMode(EN, OUTPUT);
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);
  digitalWrite(IN1, HIGH);
  digitalWrite(IN2, LOW);
  pinMode(ENC_A, INPUT_PULLUP);
  pinMode(ENC_B, INPUT_PULLUP);
  attachInterrupt(digitalPinToInterrupt(ENC_A), onA, CHANGE);
  attachInterrupt(digitalPinToInterrupt(ENC_B), onB, CHANGE);
}

void loop() {
  // Alternate between two set points so the loop has something to do.
  float target = (millis() / 4000) % 2 ? 200 : 100;

  static long lastCounts = 0;
  static unsigned long lastMs = 0;
  delay(50);
  unsigned long now = millis();
  noInterrupts();
  long c = counts;
  interrupts();
  float rpm = (c - lastCounts) / COUNTS_PER_REV * 60000.0 / (now - lastMs);
  lastCounts = c;
  lastMs = now;

  float error = target - rpm;
  integral = constrain(integral + error * 0.05, -400, 400);
  int duty = constrain(0.4 * error + 1.2 * integral, 0, 255);
  analogWrite(EN, duty);

  Serial.print("target ");
  Serial.print(target, 0);
  Serial.print("  rpm ");
  Serial.print(rpm, 1);
  Serial.print("  duty ");
  Serial.println(duty);
}