Arduino, running the sketch you wrote
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.

Hardware is all about iteration. Velxio lets you wire a circuit, program the board and run it in seconds, real firmware on a real solver, right in the browser.
DFRobot · M5Stack links on this page are affiliate links: a purchase through them earns Velxio a small commission at no extra cost to you.
Nothing on this page is a scripted animation: the firmware is compiled and executed, and the circuit around it is solved.
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.
arduino-cli or ESP-IDF compiles the sketch, then AVR8, RP2040, RISC-V, Xtensa or ARM executes it instruction by instruction. What the OLED draws and what the serial monitor prints is what the chip actually did.

ngspice compiled to WebAssembly runs a full nodal analysis about 60 times a second. GPIO pins drive real nets, ADC inputs read solved node voltages, and probes report RMS, DC and current wherever you drop them.
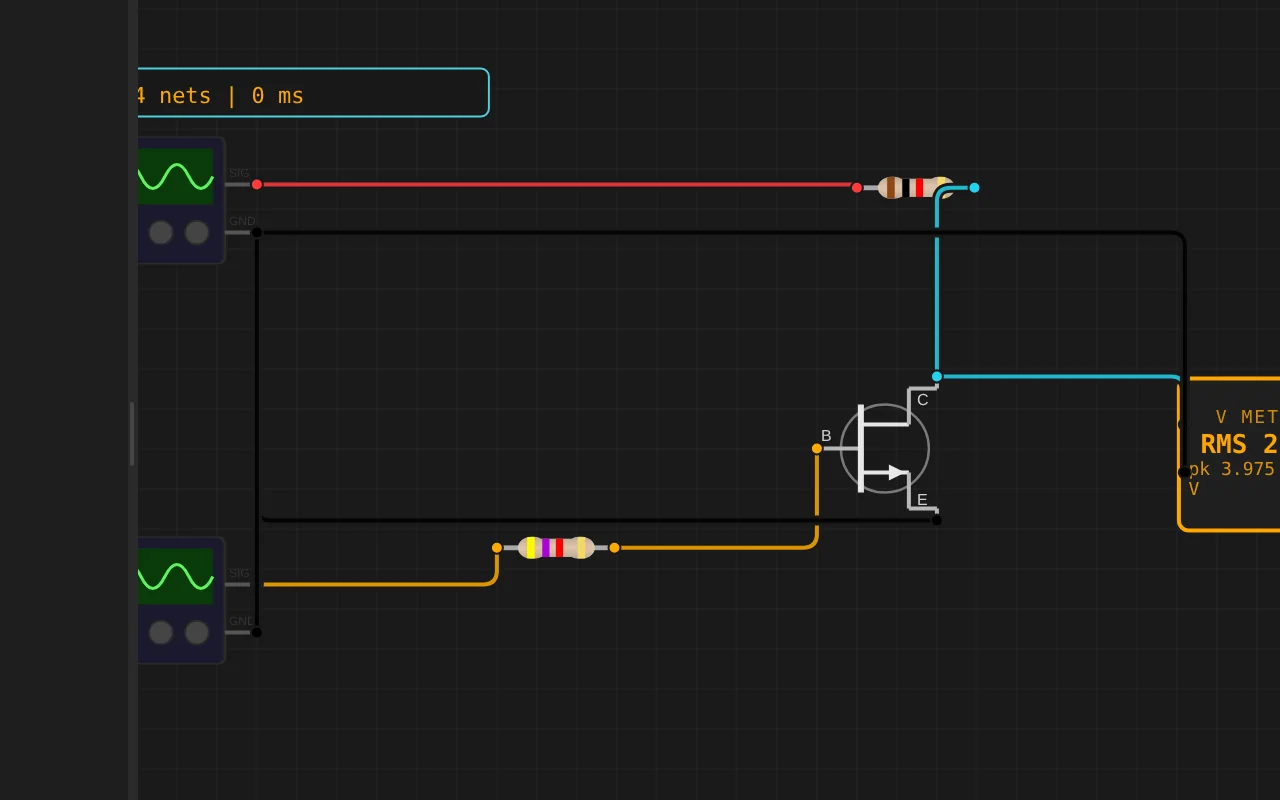
Adders, comparators, decoders, flip-flops and a 1-bit ALU slice: no microcontroller anywhere, just gates, switches and LEDs solved as a real net. The classroom half of electronics, without the breadboard.
The M5Stack Cardputer with its keyboard, Seeed's round display keeping time, Pimoroni's Badger 2350 driving e-paper, and DFRobot's UNIHIKER M10 in the catalogue alongside them. Their makers sent the hardware so the emulation could be checked against the real thing.
35 boards across 6 CPU architectures — AVR8, ARM Cortex-M, ARM Cortex-A, RISC-V, Xtensa, and Linux. Including partner boards from Pimoroni, M5Stack, Seeed Studio and DFRobot. All running locally, no cloud needed.






One institution contract gives every student in the class a full Pro account. No per-seat checkout, no card details in a classroom.
Private projects, BOM and schematic exports and GitHub Sync, for everyone enrolled.
Billed once to your institution, per semester or per year. Volume pricing on request for large cohorts.
Arduino, ESP32, RP2040, STM32, ATtiny and Raspberry Pi, with SPICE analog solved alongside the firmware. Not a sandboxed mock.
The simulator stays free forever, WiFi with internet included. Paid plans unlock the Linux and STM32 boards, custom WiFi networks and the local network gateway. Maker and Pro add the AI agent; No AI leaves it out.
Discover the simulator + light AI help.
The full workbench, zero AI. You write every line.
For makers shipping real circuits with AI help.
Private projects, GitHub Sync and BOM exports.
Questions, bugs and ideas: the Discord and the issue tracker are open, and so is every line of the simulator.
An interactive Arduino Uno circuit simulation you can run free in your browser on Velxio, by axeldissnewcool.
#include <Servo.h>

// ==========================================
// SERVOS
// ==========================================
Servo servo1;  // Base giratoria
Servo servo2;  // Alcance: acercar y alejar
Servo servo3;  // Brazo: subir y bajar
Servo servo4;  // Pinza

// ==========================================
// PINES DEL JOYSTICK
// ==========================================
const int JOY_X = A0;
const int JOY_Y = A1;
const int JOY_SW = 2;

// ==========================================
// PINES DE LOS SERVOS
// ==========================================
const int SERVO1_PIN = 3;
const int SERVO2_PIN = 5;
const int SERVO3_PIN = 6;
const int SERVO4_PIN = 9;

// ==========================================
// POSICIONES INICIALES
// ==========================================
float posServo1 = 90.0;
float posServo2 = 90.0;
float posServo3 = 90.0;
float posServo4 = 30.0;

// ==========================================
// LIMITES DE MOVIMIENTO
// ==========================================
const int SERVO1_MIN = 0;
const int SERVO1_MAX = 180;

const int SERVO2_MIN = 30;
const int SERVO2_MAX = 150;

const int SERVO3_MIN = 40;
const int SERVO3_MAX = 140;

const int PINZA_CERRADA = 30;
const int PINZA_ABIERTA = 70;

// ==========================================
// VELOCIDADES: GRADOS POR SEGUNDO
// ==========================================
const float VELOCIDAD_SERVO1 = 45.0;
const float VELOCIDAD_SERVO2 = 35.0;
const float VELOCIDAD_SERVO3 = 32.0;
const float VELOCIDAD_SERVO4 = 60.0;

// ==========================================
// CONFIGURACION DEL JOYSTICK
// ==========================================
const int ZONA_MUERTA = 80;

// ==========================================
// CAMBIO DE MODO CON UN SOLO CLIC
// ==========================================
bool modo2 = false;

bool botonAnterior = HIGH;
unsigned long ultimoCambioBoton = 0;

const unsigned long ANTIRREBOTE = 50;

// ==========================================
// CONTROL DEL TIEMPO
// ==========================================
unsigned long tiempoAnterior = 0;

const unsigned long INTERVALO = 20;

// ==========================================
// CONTROL DE PINZA EN MODO 1
// ==========================================
bool pinzaAbierta = false;

// ==========================================
// CALCULAR VELOCIDAD SEGUN JOYSTICK
// ==========================================
float calcularVelocidad(int lectura, float maxVelocidad) {

  int desviacion = lectura - 512;

  if (abs(desviacion) <= ZONA_MUERTA) {
    return 0.0;
  }

  return (desviacion / 512.0) * maxVelocidad;
}

// ==========================================
// CAMBIAR ENTRE MODOS
// ==========================================
void cambiarModo() {

  modo2 = !modo2;

  if (modo2) {
    Serial.println("========================");
    Serial.println("MODO 2: ALCANCE Y PINZA");
    Serial.println("Vertical: Servo 2");
    Serial.println("Horizontal: Servo 4");
    Serial.println("Servo 1 y Servo 3 quietos");
    Serial.println("==========