Arduino, running the sketch you wrote
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.

Hardware is all about iteration. Velxio lets you wire a circuit, program the board and run it in seconds, real firmware on a real solver, right in the browser.
DFRobot · M5Stack links on this page are affiliate links: a purchase through them earns Velxio a small commission at no extra cost to you.
Nothing on this page is a scripted animation: the firmware is compiled and executed, and the circuit around it is solved.
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.
arduino-cli or ESP-IDF compiles the sketch, then AVR8, RP2040, RISC-V, Xtensa or ARM executes it instruction by instruction. What the OLED draws and what the serial monitor prints is what the chip actually did.

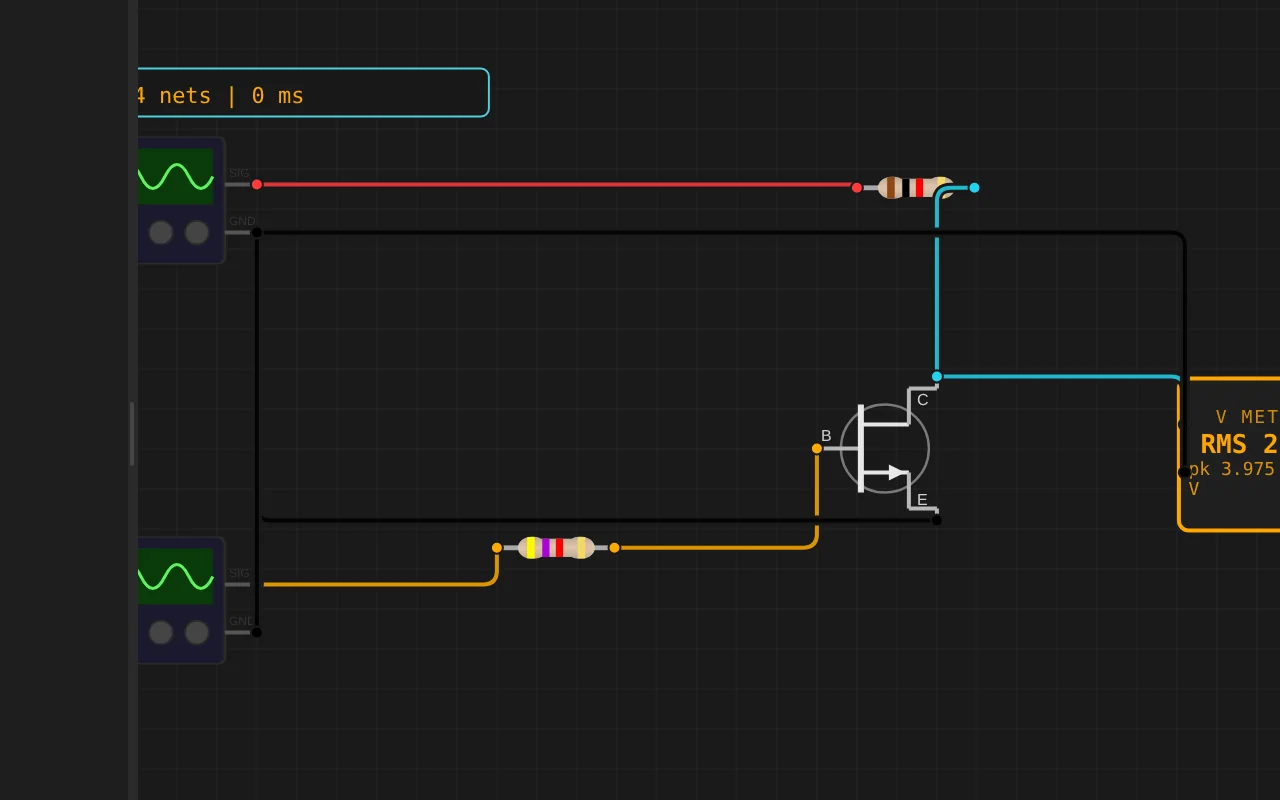
ngspice compiled to WebAssembly runs a full nodal analysis about 60 times a second. GPIO pins drive real nets, ADC inputs read solved node voltages, and probes report RMS, DC and current wherever you drop them.
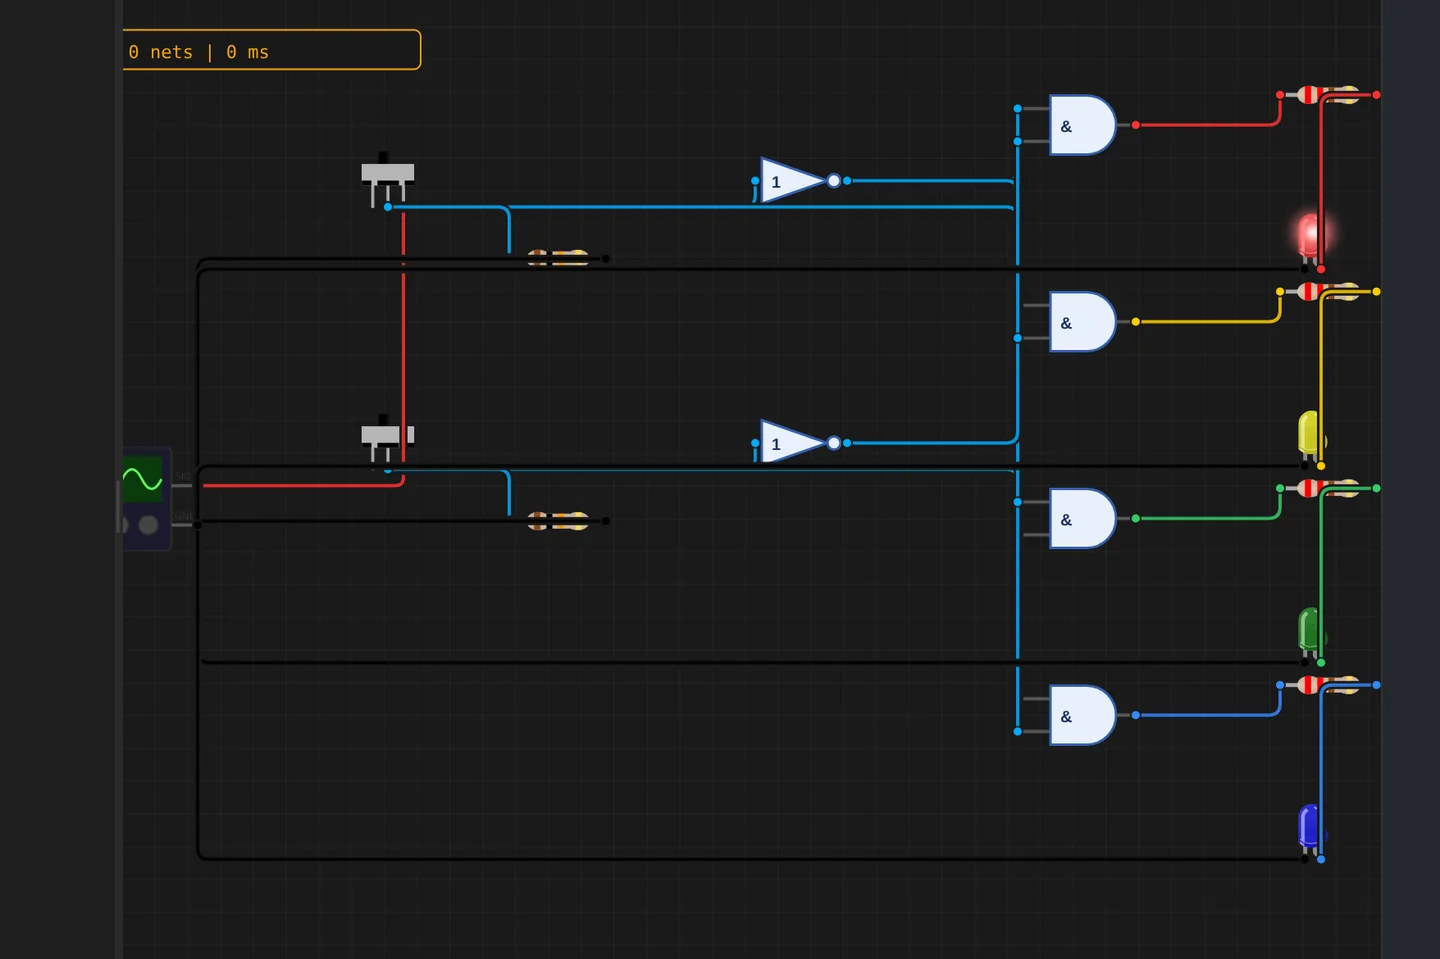
Adders, comparators, decoders, flip-flops and a 1-bit ALU slice: no microcontroller anywhere, just gates, switches and LEDs solved as a real net. The classroom half of electronics, without the breadboard.
The M5Stack Cardputer with its keyboard, Seeed's round display keeping time, Pimoroni's Badger 2350 driving e-paper, and DFRobot's UNIHIKER M10 in the catalogue alongside them. Their makers sent the hardware so the emulation could be checked against the real thing.
35 boards across 6 CPU architectures — AVR8, ARM Cortex-M, ARM Cortex-A, RISC-V, Xtensa, and Linux. Including partner boards from Pimoroni, M5Stack, Seeed Studio and DFRobot. All running locally, no cloud needed.






One institution contract gives every student in the class a full Pro account. No per-seat checkout, no card details in a classroom.
Private projects, BOM and schematic exports, GitHub Sync and the offline desktop app, for everyone enrolled.
Billed once to your institution, per semester or per year. Volume pricing on request for large cohorts.
Arduino, ESP32, RP2040, STM32, ATtiny and Raspberry Pi, with SPICE analog solved alongside the firmware. Not a sandboxed mock.
The simulator stays free forever, WiFi with internet included. Paid plans unlock the Linux and STM32 boards, custom WiFi networks, the local network gateway and the offline desktop app. Maker and Pro add the AI agent; No AI leaves it out.
Discover the simulator + light AI help.
The full workbench, zero AI. You write every line.
For makers shipping real circuits with AI help.
Private projects, GitHub Sync and BOM exports.
Questions, bugs and ideas: the Discord and the issue tracker are open, and so is every line of the simulator.
HC-SR04 ultrasonic distance sensor connected to an ESP32 DevKit, printing distance readings to serial.
An interactive ESP32 circuit simulation you can run free in your browser on Velxio, by thisisuseless888.
#include <Adafruit_GFX.h>
#include <Adafruit_SSD1306.h>
#include "ConfusedFra.h"
#include "AngryFra.h"
#include "HappyFra.h"
#include "motion.h"
#include "states.h"

enum moods {confused, angry, happy}; //only for simulation I will be adding 3 emotion states. The actual version will have more than this


float getDistance();
void emotions(moods mood);

//OLED
#define SCREEN_I2C_ADDR 0x3C // or 0x3C
#define SCREEN_WIDTH 128     // OLED display width, in pixels
#define SCREEN_HEIGHT 64     // OLED display height, in pixels
#define OLED_RST_PIN -1      // Reset pin (-1 if not available)

Adafruit_SSD1306 display(128, 64, &Wire, OLED_RST_PIN);

//sensor pinout
int ECHO = 18;
int TRIG = 5;

//Motor pinout
/*int leftMortPos = 14; //in2
int leftMortNeg = 4; //in1
int rihgtMorPos = 27; //in3
int rihgtMorNeg =23; //in4
int ENA2= 12;
int ENA1 = 26;
*/

int frame =0;

void setup() {
  pinMode(ECHO, INPUT);
  pinMode(TRIG, OUTPUT);
  pinMode(leftMortNeg, OUTPUT);
  pinMode(leftMortPos, OUTPUT);
  pinMode(rihgtMorNeg, OUTPUT);
  pinMode(rihgtMorPos, OUTPUT);
  pinMode(ENA1, OUTPUT);
  pinMode(ENA2, OUTPUT);

  Serial.begin(115200);

  //when turned on, I want him to seem as if he was sleepign adn was woken up.

  display.begin(SSD1306_SWITCHCAPVCC, SCREEN_I2C_ADDR);

}

void loop() {

  float distance = getDistance();
  updateState(distance);

  if(distance < 5)
  {
    Serial.println("Stopped");
    emotions(angry);
    STop();
  }

  else if (distance < 20.0)
  {
    Serial.println("Object in front");
    emotions(confused);

    int turn = random(0, 2);
    if( turn == 0) {
      Serial.println("Turn right");
      rightTurn();
      delay(3000);
      STop();

    }

    else{
      Serial.println("Turn left");
      //turn right = false;
      leftTurn();
      delay(3000);
      STop();
    }
  }

   else
   {
    emotions(happy);
    moveForward();
   }
}

//function to get the distance
float getDistance() {
  digitalWrite(TRIG, LOW);
  delayMicroseconds(2);

  digitalWrite(TRIG, HIGH);
  delayMicroseconds(10);

  digitalWrite(TRIG, LOW);

  int duration = pulseIn(ECHO, HIGH, 30000);
  float distance = duration * 0.034 / 2;

  Serial.print("Distance ");
  Serial.println(distance);

  return distance;
}

void emotions(moods mood)
{
  display.clearDisplay();


  switch (mood) {
    case confused:
      display.drawBitmap(32, 0, Confusedframes[frame], ConfuFRAME_WIDTH, ConfuFRAME_HEIGHT, 1);
      frame = (frame + 1) % ConfuFRAME_COUNT;

      break;
      case angry:
      display.drawBitmap(40, 8, Angryframes[frame], AngFRAME_WIDTH, AngFRAME_HEIGHT,
      1);
      frame = (frame + 1) % AngFRAME_COUNT;

      break;
      case happy:
        display.drawBitmap(40, 8, Happyframes[frame], HapFRAME_WIDTH, HapFRAME_HEIGHT, 1);
        frame = (frame + 1) % HapFRAME_COUNT;

      break;

      default:
      Serial.println("HOW DID YOU GET HERE?");
      break;

  }
   display.display();
   delay(FRAME_DELAY);

  }