Arduino, running the sketch you wrote
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.

Hardware is all about iteration. Velxio lets you wire a circuit, program the board and run it in seconds, real firmware on a real solver, right in the browser.
DFRobot · M5Stack links on this page are affiliate links: a purchase through them earns Velxio a small commission at no extra cost to you.
Nothing on this page is a scripted animation: the firmware is compiled and executed, and the circuit around it is solved.
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.
arduino-cli or ESP-IDF compiles the sketch, then AVR8, RP2040, RISC-V, Xtensa or ARM executes it instruction by instruction. What the OLED draws and what the serial monitor prints is what the chip actually did.

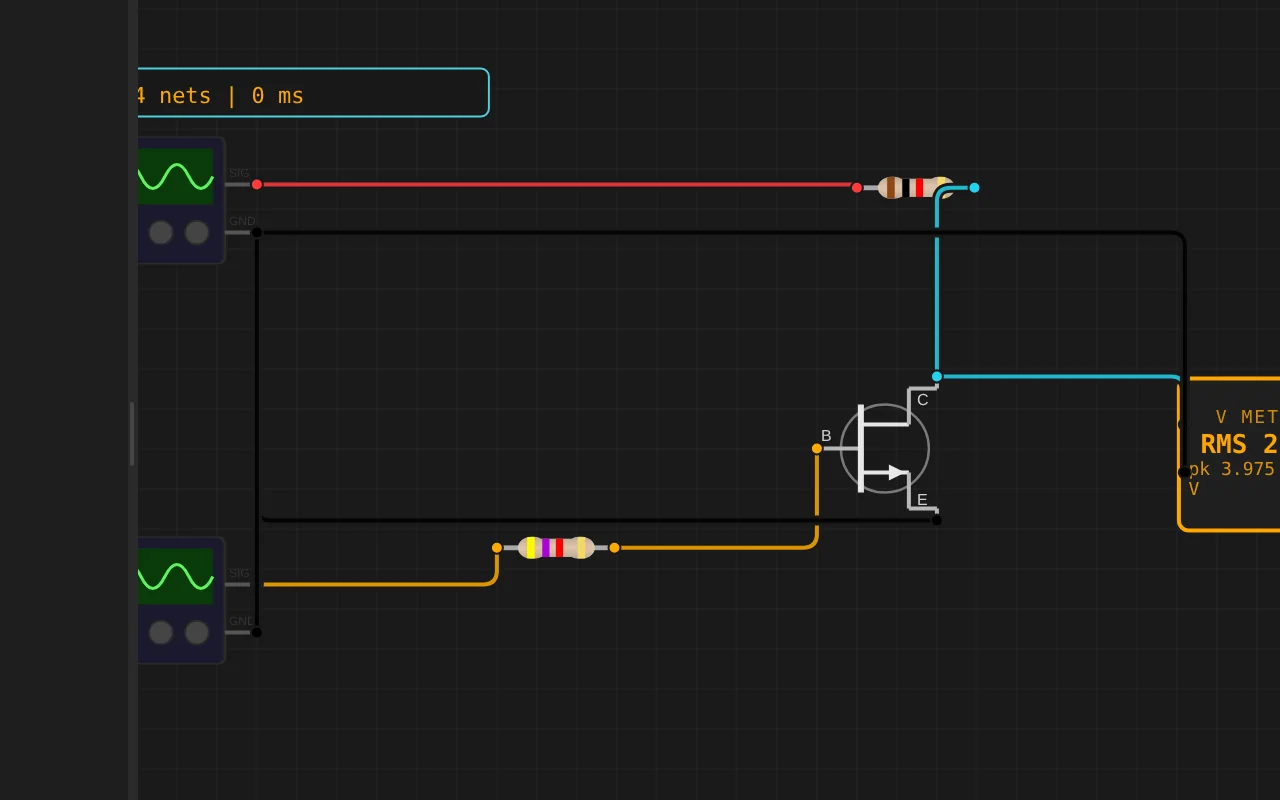
ngspice compiled to WebAssembly runs a full nodal analysis about 60 times a second. GPIO pins drive real nets, ADC inputs read solved node voltages, and probes report RMS, DC and current wherever you drop them.
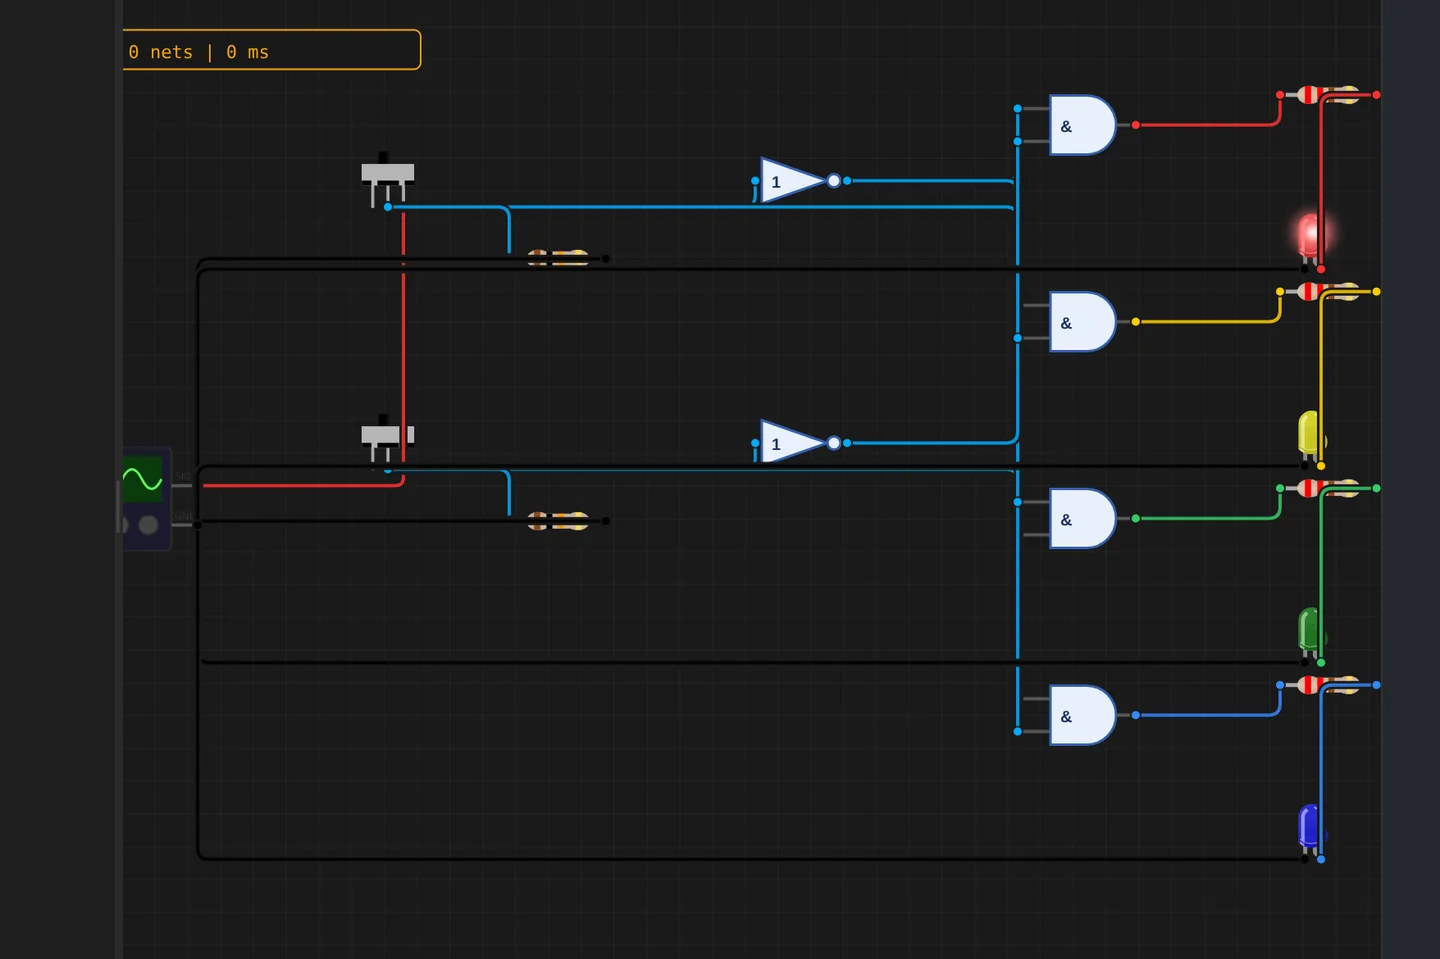
Adders, comparators, decoders, flip-flops and a 1-bit ALU slice: no microcontroller anywhere, just gates, switches and LEDs solved as a real net. The classroom half of electronics, without the breadboard.
The M5Stack Cardputer with its keyboard, Seeed's round display keeping time, Pimoroni's Badger 2350 driving e-paper, and DFRobot's UNIHIKER M10 in the catalogue alongside them. Their makers sent the hardware so the emulation could be checked against the real thing.
35 boards across 6 CPU architectures — AVR8, ARM Cortex-M, ARM Cortex-A, RISC-V, Xtensa, and Linux. Including partner boards from Pimoroni, M5Stack, Seeed Studio and DFRobot. All running locally, no cloud needed.






One institution contract gives every student in the class a full Pro account. No per-seat checkout, no card details in a classroom.
Private projects, BOM and schematic exports, GitHub Sync and the offline desktop app, for everyone enrolled.
Billed once to your institution, per semester or per year. Volume pricing on request for large cohorts.
Arduino, ESP32, RP2040, STM32, ATtiny and Raspberry Pi, with SPICE analog solved alongside the firmware. Not a sandboxed mock.
The simulator stays free forever. Paid plans unlock the Linux and STM32 boards, WiFi and the offline desktop app. Maker and Pro add the AI agent; No AI leaves it out.
Discover the simulator + light AI help.
The full workbench, zero AI. You write every line.
For makers shipping real circuits with AI help.
Private projects, GitHub Sync and BOM exports.
Questions, bugs and ideas: the Discord and the issue tracker are open, and so is every line of the simulator.
An interactive ESP32 circuit simulation you can run free in your browser on Velxio, by seifeldinm535.
// ============================================================
// FIRE FIGHTING SYSTEM - ESP32
// 4 Flame Sensors + A4988 + Relay (Pump/Fan) + 2-pin Active Buzzer
// STEPPER MOTOR - SHORTEST CIRCULAR PATH
// ============================================================


// ============================================================
// 1. FLAME SENSORS (ADC1)
// ============================================================

#define SENSOR_NORTH 34
#define SENSOR_EAST  35
#define SENSOR_SOUTH 32
#define SENSOR_WEST  33

#define ADC_MAX 4095


// ============================================================
// 2. OUTPUTS (RELAY & BUZZER)
// ============================================================

#define RELAY_PIN  26
#define BUZZER_PIN 25

// الريليه Active HIGH
#define RELAY_ON   HIGH
#define RELAY_OFF  LOW

// البازر ذو الرجلين
#define BUZZER_ON  HIGH
#define BUZZER_OFF LOW


// ============================================================
// 3. A4988 STEPPER
// ============================================================

#define STEP_PIN    18
#define DIR_PIN     19
#define ENABLE_PIN  23


// ============================================================
// 4. SENSOR CALIBRATION
// ============================================================

// إذا كان false:
// القيمة المنخفضة = نار
// القيمة العالية = لا توجد نار
#define FIRE_ACTIVE_HIGH false

// عتبة اكتشاف النار
#define FIRE_THRESHOLD   2200

// hysteresis لمنع التذبذب
#define FIRE_HYSTERESIS  250

// هامش تبديل الاتجاه
#define SWITCH_MARGIN    100

// زمن استمرار تشغيل المضخة والبازر بعد اختفاء النار
#define FIRE_HOLD_TIME_MS 1500


// ============================================================
// 5. STEPPER POSITIONS
// ============================================================

// الموتور يحتاج 200 خطوة للدورة الكاملة
#define STEPS_PER_REV 200

// مواقع الاتجاهات
#define POS_NORTH 0
#define POS_EAST  50
#define POS_SOUTH 100
#define POS_WEST  150

// الموقع الحالي للموتور
int currentPosition = POS_NORTH;


// ============================================================
// 6. DATA TABLES
// ============================================================

const int SENSOR_PINS[4] = {
  SENSOR_NORTH,
  SENSOR_EAST,
  SENSOR_SOUTH,
  SENSOR_WEST
};

const int POSITIONS[4] = {
  POS_NORTH,
  POS_EAST,
  POS_SOUTH,
  POS_WEST
};

const char* NAMES[4] = {
  "NORTH",
  "EAST",
  "SOUTH",
  "WEST"
};


// ============================================================
// 7. SENSOR STATES
// ============================================================

bool sensorFire[4] = {
  false,
  false,
  false,
  false
};


// ============================================================
// 8. STATE TRACKING
// ============================================================

int activeDirection = -1;

bool fireActive = false;
bool pumpIsOn = false;
bool buzzerIsOn = false;

unsigned long lastFireDetectMs = 0;


// ============================================================
// READ SENSOR
// متوسط 8 قراءات لت