Arduino, running the sketch you wrote
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.

Hardware is all about iteration. Velxio lets you wire a circuit, program the board and run it in seconds, real firmware on a real solver, right in the browser.
DFRobot · M5Stack links on this page are affiliate links: a purchase through them earns Velxio a small commission at no extra cost to you.
Nothing on this page is a scripted animation: the firmware is compiled and executed, and the circuit around it is solved.
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.
arduino-cli or ESP-IDF compiles the sketch, then AVR8, RP2040, RISC-V, Xtensa or ARM executes it instruction by instruction. What the OLED draws and what the serial monitor prints is what the chip actually did.

ngspice compiled to WebAssembly runs a full nodal analysis about 60 times a second. GPIO pins drive real nets, ADC inputs read solved node voltages, and probes report RMS, DC and current wherever you drop them.
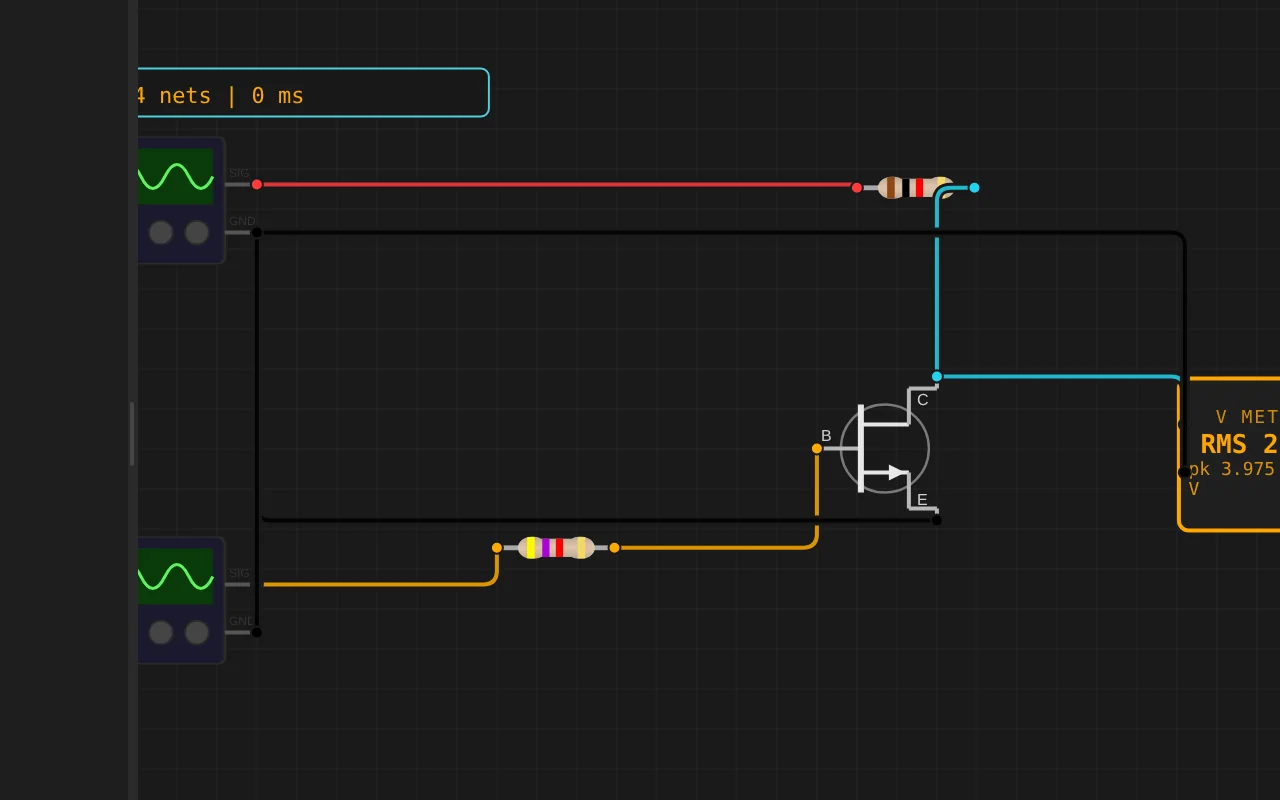
Adders, comparators, decoders, flip-flops and a 1-bit ALU slice: no microcontroller anywhere, just gates, switches and LEDs solved as a real net. The classroom half of electronics, without the breadboard.
The M5Stack Cardputer with its keyboard, Seeed's round display keeping time, Pimoroni's Badger 2350 driving e-paper, and DFRobot's UNIHIKER M10 in the catalogue alongside them. Their makers sent the hardware so the emulation could be checked against the real thing.
35 boards across 6 CPU architectures — AVR8, ARM Cortex-M, ARM Cortex-A, RISC-V, Xtensa, and Linux. Including partner boards from Pimoroni, M5Stack, Seeed Studio and DFRobot. All running locally, no cloud needed.






One institution contract gives every student in the class a full Pro account. No per-seat checkout, no card details in a classroom.
Private projects, BOM and schematic exports, GitHub Sync and the offline desktop app, for everyone enrolled.
Billed once to your institution, per semester or per year. Volume pricing on request for large cohorts.
Arduino, ESP32, RP2040, STM32, ATtiny and Raspberry Pi, with SPICE analog solved alongside the firmware. Not a sandboxed mock.
The simulator stays free forever, WiFi with internet included. Paid plans unlock the Linux and STM32 boards, custom WiFi networks, the local network gateway and the offline desktop app. Maker and Pro add the AI agent; No AI leaves it out.
Discover the simulator + light AI help.
The full workbench, zero AI. You write every line.
For makers shipping real circuits with AI help.
Private projects, GitHub Sync and BOM exports.
Questions, bugs and ideas: the Discord and the issue tracker are open, and so is every line of the simulator.
An interactive Arduino Uno circuit simulation you can run free in your browser on Velxio, by knlkmr2004.
/*
  ============================================================
        EXPERIMENTAL ACTIVE BRIDGE BATTERY CHARGER
        Arduino UNO + 2 x IR2110 + 4 x N-MOSFET
        + ACS712 + 20x4 I2C LCD + AC RELAY
  ============================================================

  MOSFET / IR2110 CONTROL
  ------------------------

  IR2110 #1
      HIN -> D9  -> Q1
      LIN -> D10 -> Q3

  IR2110 #2
      HIN -> D11 -> Q2
      LIN -> D3  -> Q4

  SENSOR INPUTS
  -------------
      D2  = Zero-cross detector
      A0  = Battery voltage
      A1  = ACS712 current
      D4  = Fault input, LOW = fault

  RELAY
  -----
      D5 = 5V relay module input

      Relay ON  = transformer primary connected
      Relay OFF = transformer primary disconnected

  ASSUMPTION
  ----------
      Relay module is ACTIVE-LOW.
      Change RELAY_ACTIVE_LOW to false if yours is active-HIGH.

  BATTERY
  -------
      Target = 14.40 V
      Stop   = 14.45 V

  CURRENT
  -------
      Normal target = 0.30 A
      Hard shutdown = 0.50 A

  PWM
  ---
      20 kHz Timer1 PWM timing

  IMPORTANT
  ----------
  This is experimental power-electronics firmware.
  Verify the IR2110 gate outputs with the power stage
  disconnected before applying battery/transformer power.
*/


#include <Wire.h>
#include <LiquidCrystal_I2C.h>

LiquidCrystal_I2C lcd(0x27, 20, 4);


// ============================================================
// PIN DEFINITIONS
// ============================================================

#define Q1_PIN  9
#define Q3_PIN  10

#define Q2_PIN  11
#define Q4_PIN  3

#define ZCD_PIN 2

#define BAT_PIN A0
#define ACS_PIN A1

#define FAULT_PIN 4

#define RELAY_PIN 5


// ============================================================
// RELAY CONFIGURATION
// ============================================================

#define RELAY_ACTIVE_LOW true

bool relayState = false;


// ============================================================
// BATTERY SETTINGS
// ============================================================

const float BAT_TARGET = 14.40;
const float BAT_STOP   = 14.45;


// ============================================================
// CHARGE CURRENT SETTINGS
// ============================================================

const float CHARGE_CURRENT = 0.30;
const float HARD_CURRENT   = 0.50;


// ============================================================
// ACS712-30A
// ============================================================

const float ACS_SENSITIVITY = 0.066;

float acsZero = 512.0;


// ============================================================
// BATTERY VOLTAGE DIVIDER
//
// 30k TOP
// 10k BOTTOM
//
// Ratio = 4
// ============================================================

const float R_TOP    = 30000.0;
const float R_BOTTOM = 10000.0;

const float ADC_REFERENCE = 5.0;


// ============================================================
// PWM SETTINGS
//
// Arduino UNO:
//
// 16 MHz / 800 = 20 kHz
//
// TOP = 799
// =======================