Arduino, running the sketch you wrote
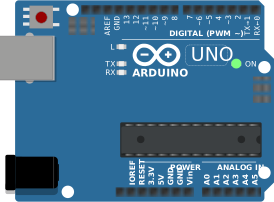
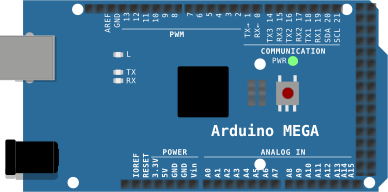
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.

Hardware is all about iteration. Velxio lets you wire a circuit, program the board and run it in seconds, real firmware on a real solver, right in the browser.
DFRobot · M5Stack links on this page are affiliate links: a purchase through them earns Velxio a small commission at no extra cost to you.
Nothing on this page is a scripted animation: the firmware is compiled and executed, and the circuit around it is solved.
arduino-cli compiles it, an AVR8 core executes it instruction by instruction, and the LCD shows what the ATmega328P actually put on the bus. Uno, Nano, Mega and ATtiny85, no board on your desk.
arduino-cli or ESP-IDF compiles the sketch, then AVR8, RP2040, RISC-V, Xtensa or ARM executes it instruction by instruction. What the OLED draws and what the serial monitor prints is what the chip actually did.

ngspice compiled to WebAssembly runs a full nodal analysis about 60 times a second. GPIO pins drive real nets, ADC inputs read solved node voltages, and probes report RMS, DC and current wherever you drop them.
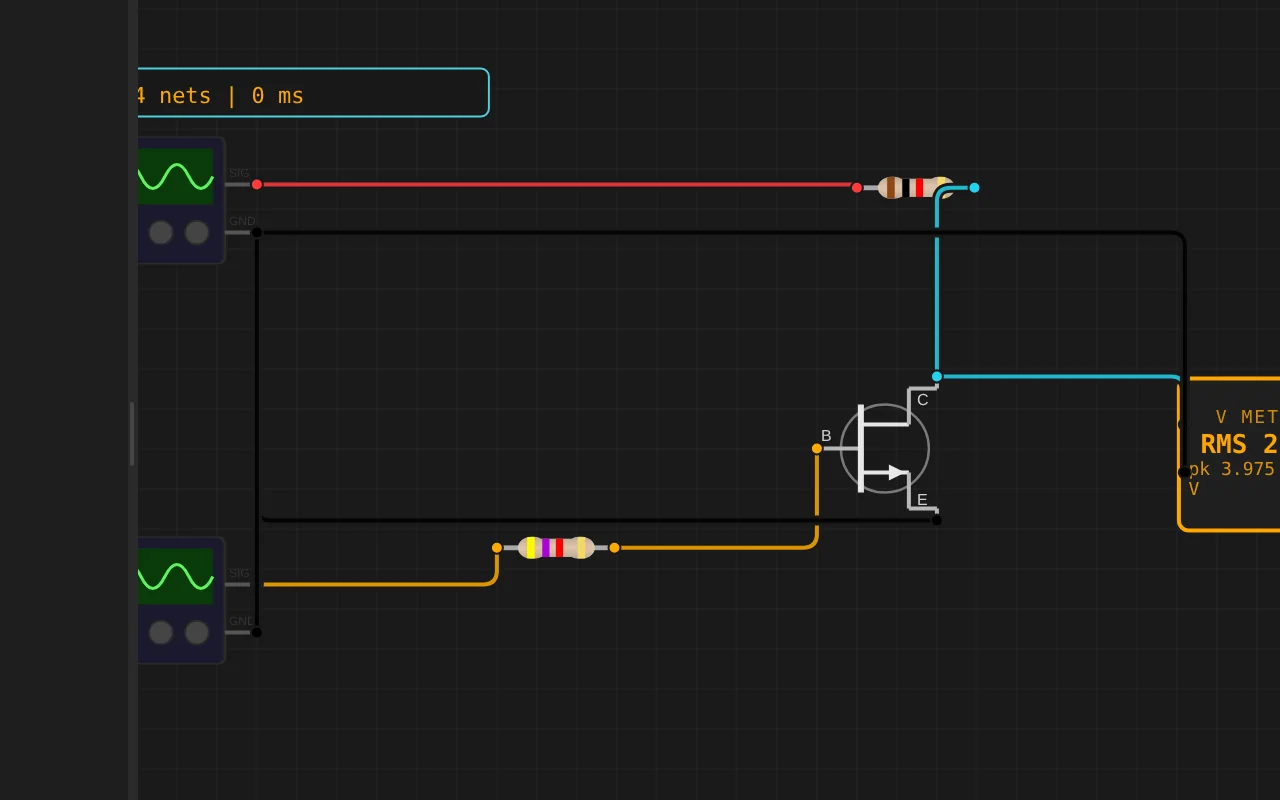
Adders, comparators, decoders, flip-flops and a 1-bit ALU slice: no microcontroller anywhere, just gates, switches and LEDs solved as a real net. The classroom half of electronics, without the breadboard.
The M5Stack Cardputer with its keyboard, Seeed's round display keeping time, Pimoroni's Badger 2350 driving e-paper, and DFRobot's UNIHIKER M10 in the catalogue alongside them. Their makers sent the hardware so the emulation could be checked against the real thing.
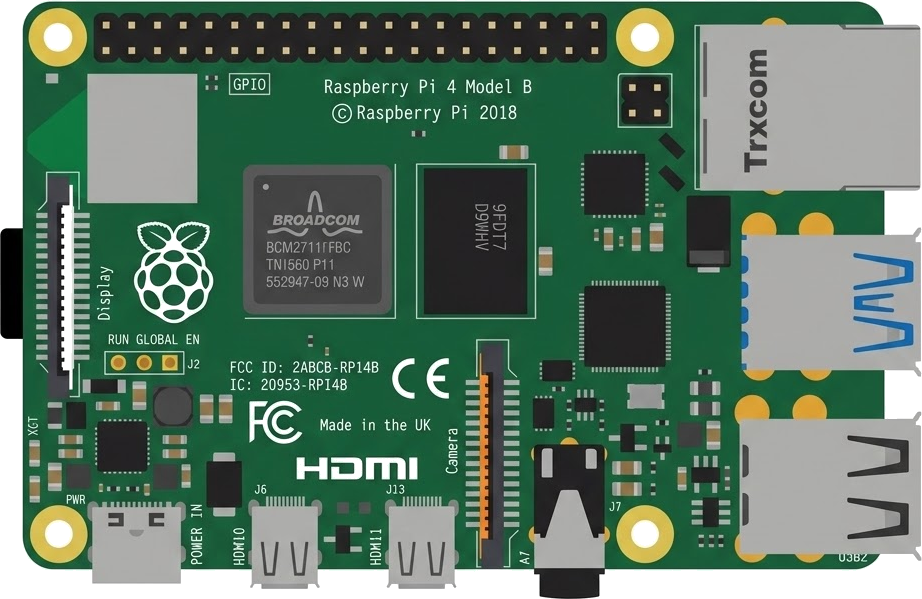
35 boards across 6 CPU architectures — AVR8, ARM Cortex-M, ARM Cortex-A, RISC-V, Xtensa, and Linux. Including partner boards from Pimoroni, M5Stack, Seeed Studio and DFRobot. All running locally, no cloud needed.






One institution contract gives every student in the class a full Pro account. No per-seat checkout, no card details in a classroom.
Private projects, BOM and schematic exports, GitHub Sync and the offline desktop app, for everyone enrolled.
Billed once to your institution, per semester or per year. Volume pricing on request for large cohorts.
Arduino, ESP32, RP2040, STM32, ATtiny and Raspberry Pi, with SPICE analog solved alongside the firmware. Not a sandboxed mock.
The simulator stays free forever. Paid plans raise the daily AI quota and unlock the Linux boards, private projects and the offline desktop app.
Discover the simulator + light AI help.
For makers shipping real circuits with AI help.
Private projects, GitHub Sync and BOM exports.
Questions, bugs and ideas: the Discord and the issue tracker are open, and so is every line of the simulator.
An Autonomous Vision-Based Following Cart
An interactive ESP32 circuit simulation you can run free in your browser on Velxio, by 24155714.
#include <Wire.h>

// =====================================================
// MOTOR DRIVER PINS
// =====================================================

#define EN1 25
#define IN1 26
#define IN2 27

#define EN2 14
#define IN3 12
#define IN4 13

// =====================================================
// LEFT TOF
// SDA -> GPIO 21
// SCL -> GPIO 22
// =====================================================

#define LEFT_SDA 21
#define LEFT_SCL 22

// =====================================================
// RIGHT TOF
// SDA -> GPIO 18
// SCL -> GPIO 19
// =====================================================

#define RIGHT_SDA 18
#define RIGHT_SCL 19

// =====================================================
// VL53L0X I2C ADDRESS
// =====================================================

#define TOF_ADDR 0x29

// Second I2C bus
TwoWire I2C_Right = TwoWire(1);

// =====================================================
// READ 8-BIT REGISTER
// =====================================================

uint8_t reg8(TwoWire &bus, uint8_t reg) {

  bus.beginTransmission(TOF_ADDR);
  bus.write(reg);
  bus.endTransmission();

  bus.requestFrom(TOF_ADDR, (uint8_t)1);

  if (bus.available()) {
    return bus.read();
  }

  return 0;
}

// =====================================================
// READ 16-BIT REGISTER
// =====================================================

uint16_t reg16(TwoWire &bus, uint8_t reg) {

  bus.beginTransmission(TOF_ADDR);
  bus.write(reg);
  bus.endTransmission();

  bus.requestFrom(TOF_ADDR, (uint8_t)2);

  if (bus.available() >= 2) {

    uint16_t highByte = bus.read();
    uint16_t lowByte = bus.read();

    return (highByte << 8) | lowByte;
  }

  return 0;
}

// =====================================================
// START VL53L0X CONTINUOUS RANGING
// =====================================================

void startToF(TwoWire &bus) {

  bus.beginTransmission(TOF_ADDR);

  bus.write(0x00);
  bus.write(0x02);

  bus.endTransmission();
}

// =====================================================
// CHECK SENSOR
// =====================================================

bool checkToF(TwoWire &bus) {

  uint8_t modelID = reg8(bus, 0xC0);

  Serial.print("Model ID: 0x");
  Serial.println(modelID, HEX);

  return (modelID == 0xEE);
}

// =====================================================
// READ DISTANCE
// =====================================================

int readDistance(TwoWire &bus) {

  uint16_t distance = reg16(bus, 0x1E);

  if (distance == 0) {
    return -1;
  }

  return distance;
}

// =====================================================
// STOP
// =====================================================

void stopMotors() {

  digitalWrite(EN1, LOW);
  digitalWrite(EN2, LOW);

  digitalWrite(IN1, LOW);
  digitalWrite(IN2, LOW);

  digitalWrite(IN3, LOW);
  digitalWrite(IN4, LOW);
}

// =====================================================
// FORWARD
// =====================================================

void forwa